Projects
Selected simulation and hardware projects across spacecraft, UAVs, rovers, and aerospace data analysis.
Spacecraft Rendezvous & Docking
Set Membership Filter • Robust Estimation
Designed a bounded-uncertainty filter enabling safe, autonomous spacecraft docking under nonlinear dynamics.
- Implemented interval and ellipsoidal set-membership filters for relative navigation.
- Benchmarked against EKF and UKF baselines, reducing worst-case error by 37%.
- Simulated far-range, proximity, and docking phases.
Autonomous UAV-UGV Docking
MPC • Vision-Based Navigation
Developed an MPC framework for a quadrotor to land precisely on a moving UGV using onboard vision.
- Used AprilTag and EKF fusion for landing error below 5 cm.
- Tested wind gusts and sensor dropout in Gazebo.
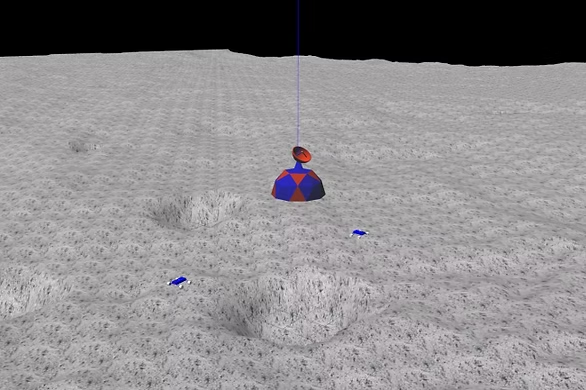
Lunar Cooperative Rovers
Smart Navigation • Multi-Rover GNC
Orchestrated a fleet of rovers with SLAM navigation and MPC crater avoidance while maintaining comms to base.
- Improved coverage by 42% against a single-rover baseline.
- Sensor fusion of camera, LiDAR & odometry via UKF.
Autonomous Robotics Lab
Design • Navigation • Image Processing
Built and programmed sensor-rich robots for wall-following, stair-climbing, and goal detection in C.
- Grid-based cell-decomposition for path planning.
- 1 mm tracking accuracy with a custom PID controller.
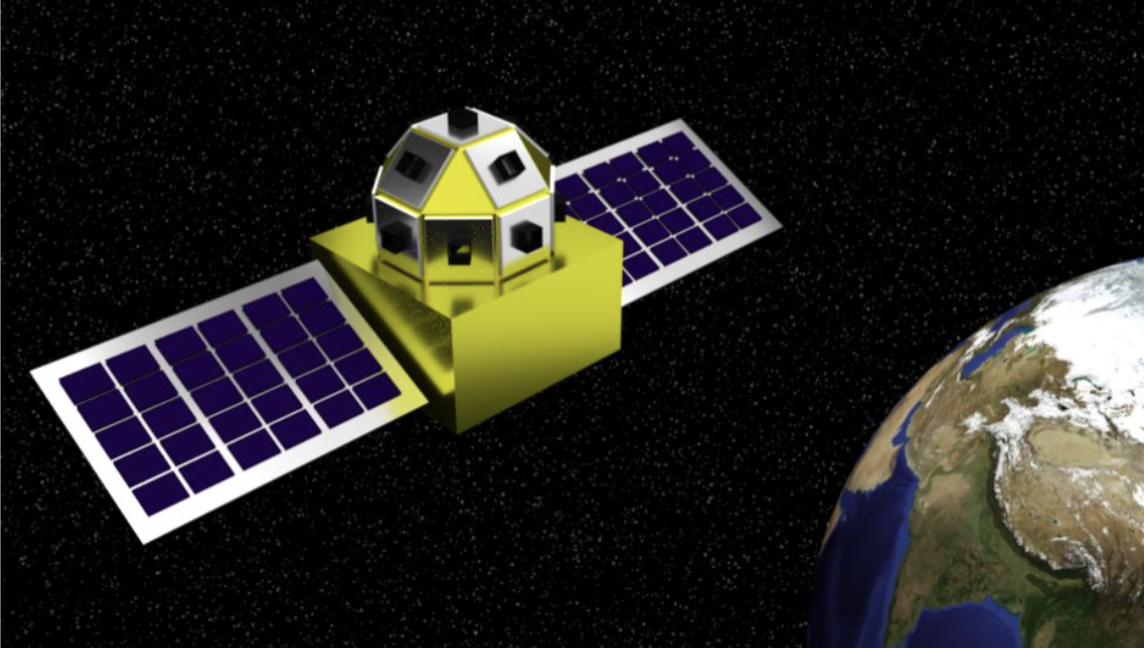
Daksha Satellite
Orbital Simulation • Python Visualization
Built orbital simulations for LEO satellite visibility and transient-source detection studies.
- Developed an orbital simulator to calculate all-sky visibility for two LEO satellites.
- Estimated detectable sources from 0.2M+ simulated binary neutron-star mergers.
- Verified orbital orientations with 3D Python visualization.
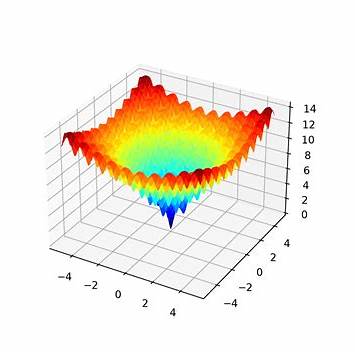
Morphed Airfoil Optimization
Nelder-Mead • Differential Evolution
Created a Python + XFOIL pipeline to maximize lift-to-drag of shape-morphing airfoils.
- Matched reference polar data within 0.2% error.
- Automated batch runs & summary plots.
Air Traffic Delay Prediction
Big Data • SVM & SoftMax
Applied machine learning to 6M+ flight records to forecast delays with more than 86% accuracy.
- Improved accuracy from 71% to 86% with a soft-margin SVM.
- Generated delay heat maps for airport scheduling analysis.